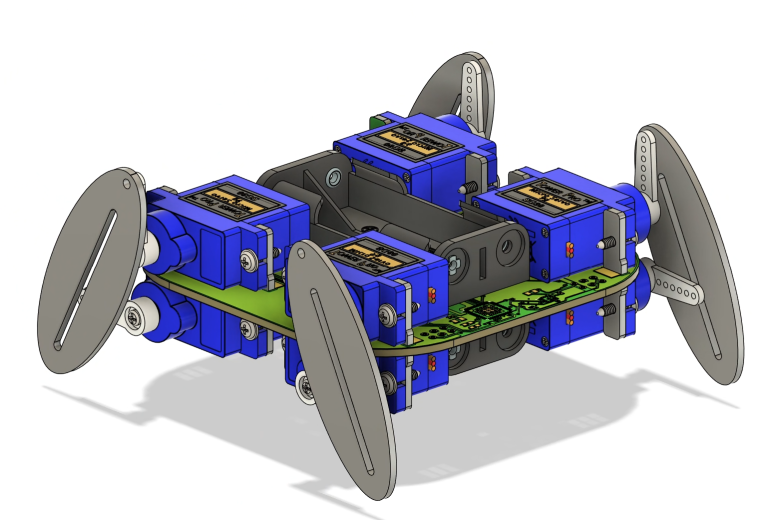
The Lavandula Project: A Quadrupedal Robot Design
The Lavandula is a DIY project for a four-legged robot. The design utilizes a custom PCB and basic electronic components, and is built to be a platform for exploring microcontroller-driven motion and sensor feedback. This page provides a complete overview of the parts and PCB specifications you will need to complete this build.
[PDF file with the component list and links to other suppliers.]
The build process is covered in the attached video and mounting position and orientation of the components on the PCB is in the images below. We have developed sample software which is available on GitHub [link]. To upload the code, connect your project with any standard USB-UART converter ([link to general converters]). Follow the upload instructions in the README file based on your software or operating system. The programming port on Lavandula has 6 pins, 1,2 are power, 3,4 are BOOT and RST, 5 and 6 are RX and TX UART. You will need to connect 3 to ground when resting in order to enter download mode.